
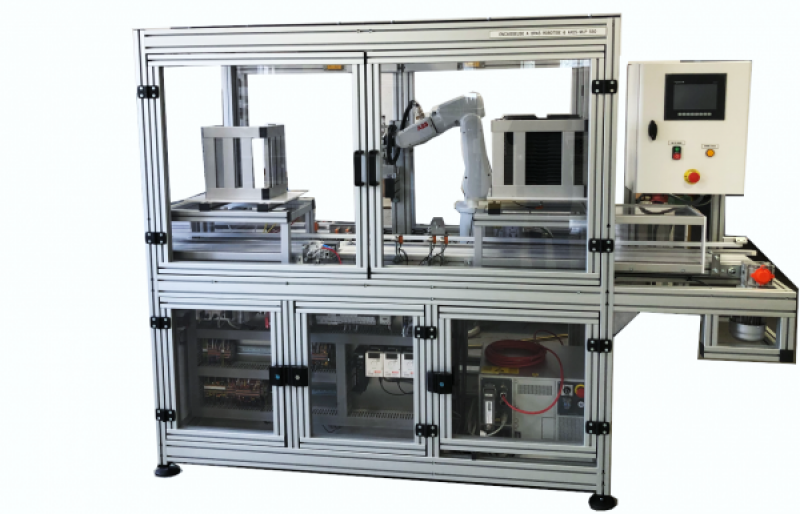
MLP 550 - Packaging machine with 6 axes robotic arm
Study and control of a robotic arm 6 axes of brand ABB for example in the automotive industry on manufacturing lines or for packaging type ‘Pick & Place’ of manufactured goods or packaging unit such as jars or bottles
The robust design of this device makes it suitable for use in schools.
The equipment is set up on an Anodized aluminium frame on casters wheels. This gives it great strength and a flexibility of integration into your premises.
The manufacture of this equipment complies with the European standard for machinery manufacturing.
This equipment can be used alone or with other compatible equipment from our range (see last section of this document).
Need more information?
Contact us- Production line management: format change following production sheets & process, mechanical adjustments, tooling changes following type of crate, lid, container, taken by 1 or 2 …
- Configuration of the application according to the types of containers, crates with or without lid, the number of container per crate & their inside disposal, the quantity to produce crate, execution speed of the robot
|
- Preventive maintenance: setting, control of operating conditions, validation and testing.
- Technical and Functional analysis, industrial maintenance organization
- This machine consisted of conveyors powered by variators (the production rate management). An additional variator enables the electrical supply of a feed table or a angle gear positioned upstream via a Type harting connector
ü Transfert of products:
ü One ensures the supply of products to put in crate and can be operated manually or come from MLP205 bench, MLP335 or MLP345 placed upstream:
- conveyor of productswith carrier beam in aluminum / Ensures the supply of bottles and jars, equipped with adjustable side rail and centering plates of interchangeable containers. Providing the centering plates of different sizes for robot configuration activity: possibility given to the operator via the HMI to adjust the arm position for proper management of containers.
- optical sensors & capacitive for detection of the products for the various positions (management of saturations)
- regulating cylinder of flow of products (ginner system) equipped with ILS detectors and controlled by solenoid valve 5/2.
ü Transfer of plastic bins:
The 2nd ensures the circulation of the bins provided in two dimensions that can then be queued above in production output or evacuated towards the palletizer MLP700 placed downstream:
- Belt conveyor equipped with adjustable guide rails depending on the formats of bins
- Optical detectors of presence of the bins at different stages (management of saturations).
- Cylinders of regulating the movement of bins, controlled by electrodistributors 5/2 (& abutting & flanging of crate)
- Pressure switches and ILS sensors for detecting cylinder positions
- Pressure regulator with manometer for pressure control exerted on the crates during their maintenance
- Chargers with lid:
Interchangeable removable storerooms localized (with capacitive presence detection) for 2 cover sizes are provided (Multiplication of format change activities)
- Gripper, robot arm multi-tool:
The establishment of the products into the bins and lids is performed by a robotic arm 6 axes (ABB brand) equipped with two types of gripping:
- with suction cup for taking of the lids in distribution chargers (2 size lids provided)
- via a clamp with interchangeable jaws according to the type and number of products to be taken: multiplication of change activities of crating recipe
- Cylinder parallel clamp oversized to support the educational use. 4 pairs of easily interchangeable clamps (locating pin, and setting up the robot via the HMI in the position dedicated to tooling change), for gripping by one or two of bottle or jar
- Use of pressure switch, vacuum switch, PNP sensors, and programmable optical sensor for embedded control actuators at arm’s length. Backup file
- Programming via a console (FlexPendant) equipped with a joystick (initial reference point, trajectory, etc …)
- The operator can select the following parameters directly via the HMI of the machine without using the FlexPendant of the arm:
ü Number of crates
ü The placement of containers in the small or large crate
ü The robot’s manual control (setting initial position or position tooling change )
ü The manual control of the arm length actuators (suction clamp & cover of gripping)
ü The average speed, fast & possibility to shift the taking of the bottles
- The tooling mounted at the end makes it possible to achieve an execution radius of 700mm. The different robot work stations were positioned to allow you to highlight the magnitude of possible use as well as the execution speed of the robot
- 3D simulation software tool PHL ROBOT STUDIO
This offline programming software and robotic cell simulation runs in the Windows environment on PC and includes a set of functions and software modules that meet the following demands
- Study of robotic cell implantation,
- Generation of trajectories according to geometric data in 3D to SAT format
- Edition of robot programs and system settings
- Test and development of robot programs,
- Cycle time estimation, analysis and optimization of existing trajectories,
- Training of operating personnel and of programming.
Its functions ‘on line’ adds the connection by Ethernet to the real robot cabinets for transfers of trajectories (of the robot towards the RobotStudio software and vice versa), the editing of the programs and system settings. This software is provided with a network license for 100 simultaneous users.
The main added value of this product is its operation "off-line" on the PC, which allows the realization of these tasks without tying up your tool of "production" through technology "Virtual Robot", unique to ABB.
You have the ability to carry out practical work in the room:
- Risk reduction by visualizing and confirming the technical solutions before the industrial establishment,
- Introduction of new parts or modification of existing parts without stopping production,
- Optimizing of robot programs to increase the productivity without stopping production.
- Obtaining a better quality of parts through the creation of more accurate trajectories
- Reproduce closely the operation of the real robot on a PC.
The programs and system settings can be exchanged directly between the real robots and the PC, and vice versa, to be edited and tested offline
"Virtual RobotTM" – the virtual robot – is a proper technology to ABB, which faithfully reproduces the operation of the real robot on a PC.
Programs and system parameters can be exchanged directly between the real robots and PC, and vice versa, to be edited and tested offline
- Electrical supply : 400 Vac – 50 Hz – 20 A
- Compressed air supply: 6-8 bars (dry air)
- Dimensions: (LxWxH mm): 3100 x 1000 x 2000
- weight (Kg): 350
Other equipment that may suit you
See the full catalogue
Production lines
Production lines
Production lines
Production lines
MLP 335